教材资源 Books
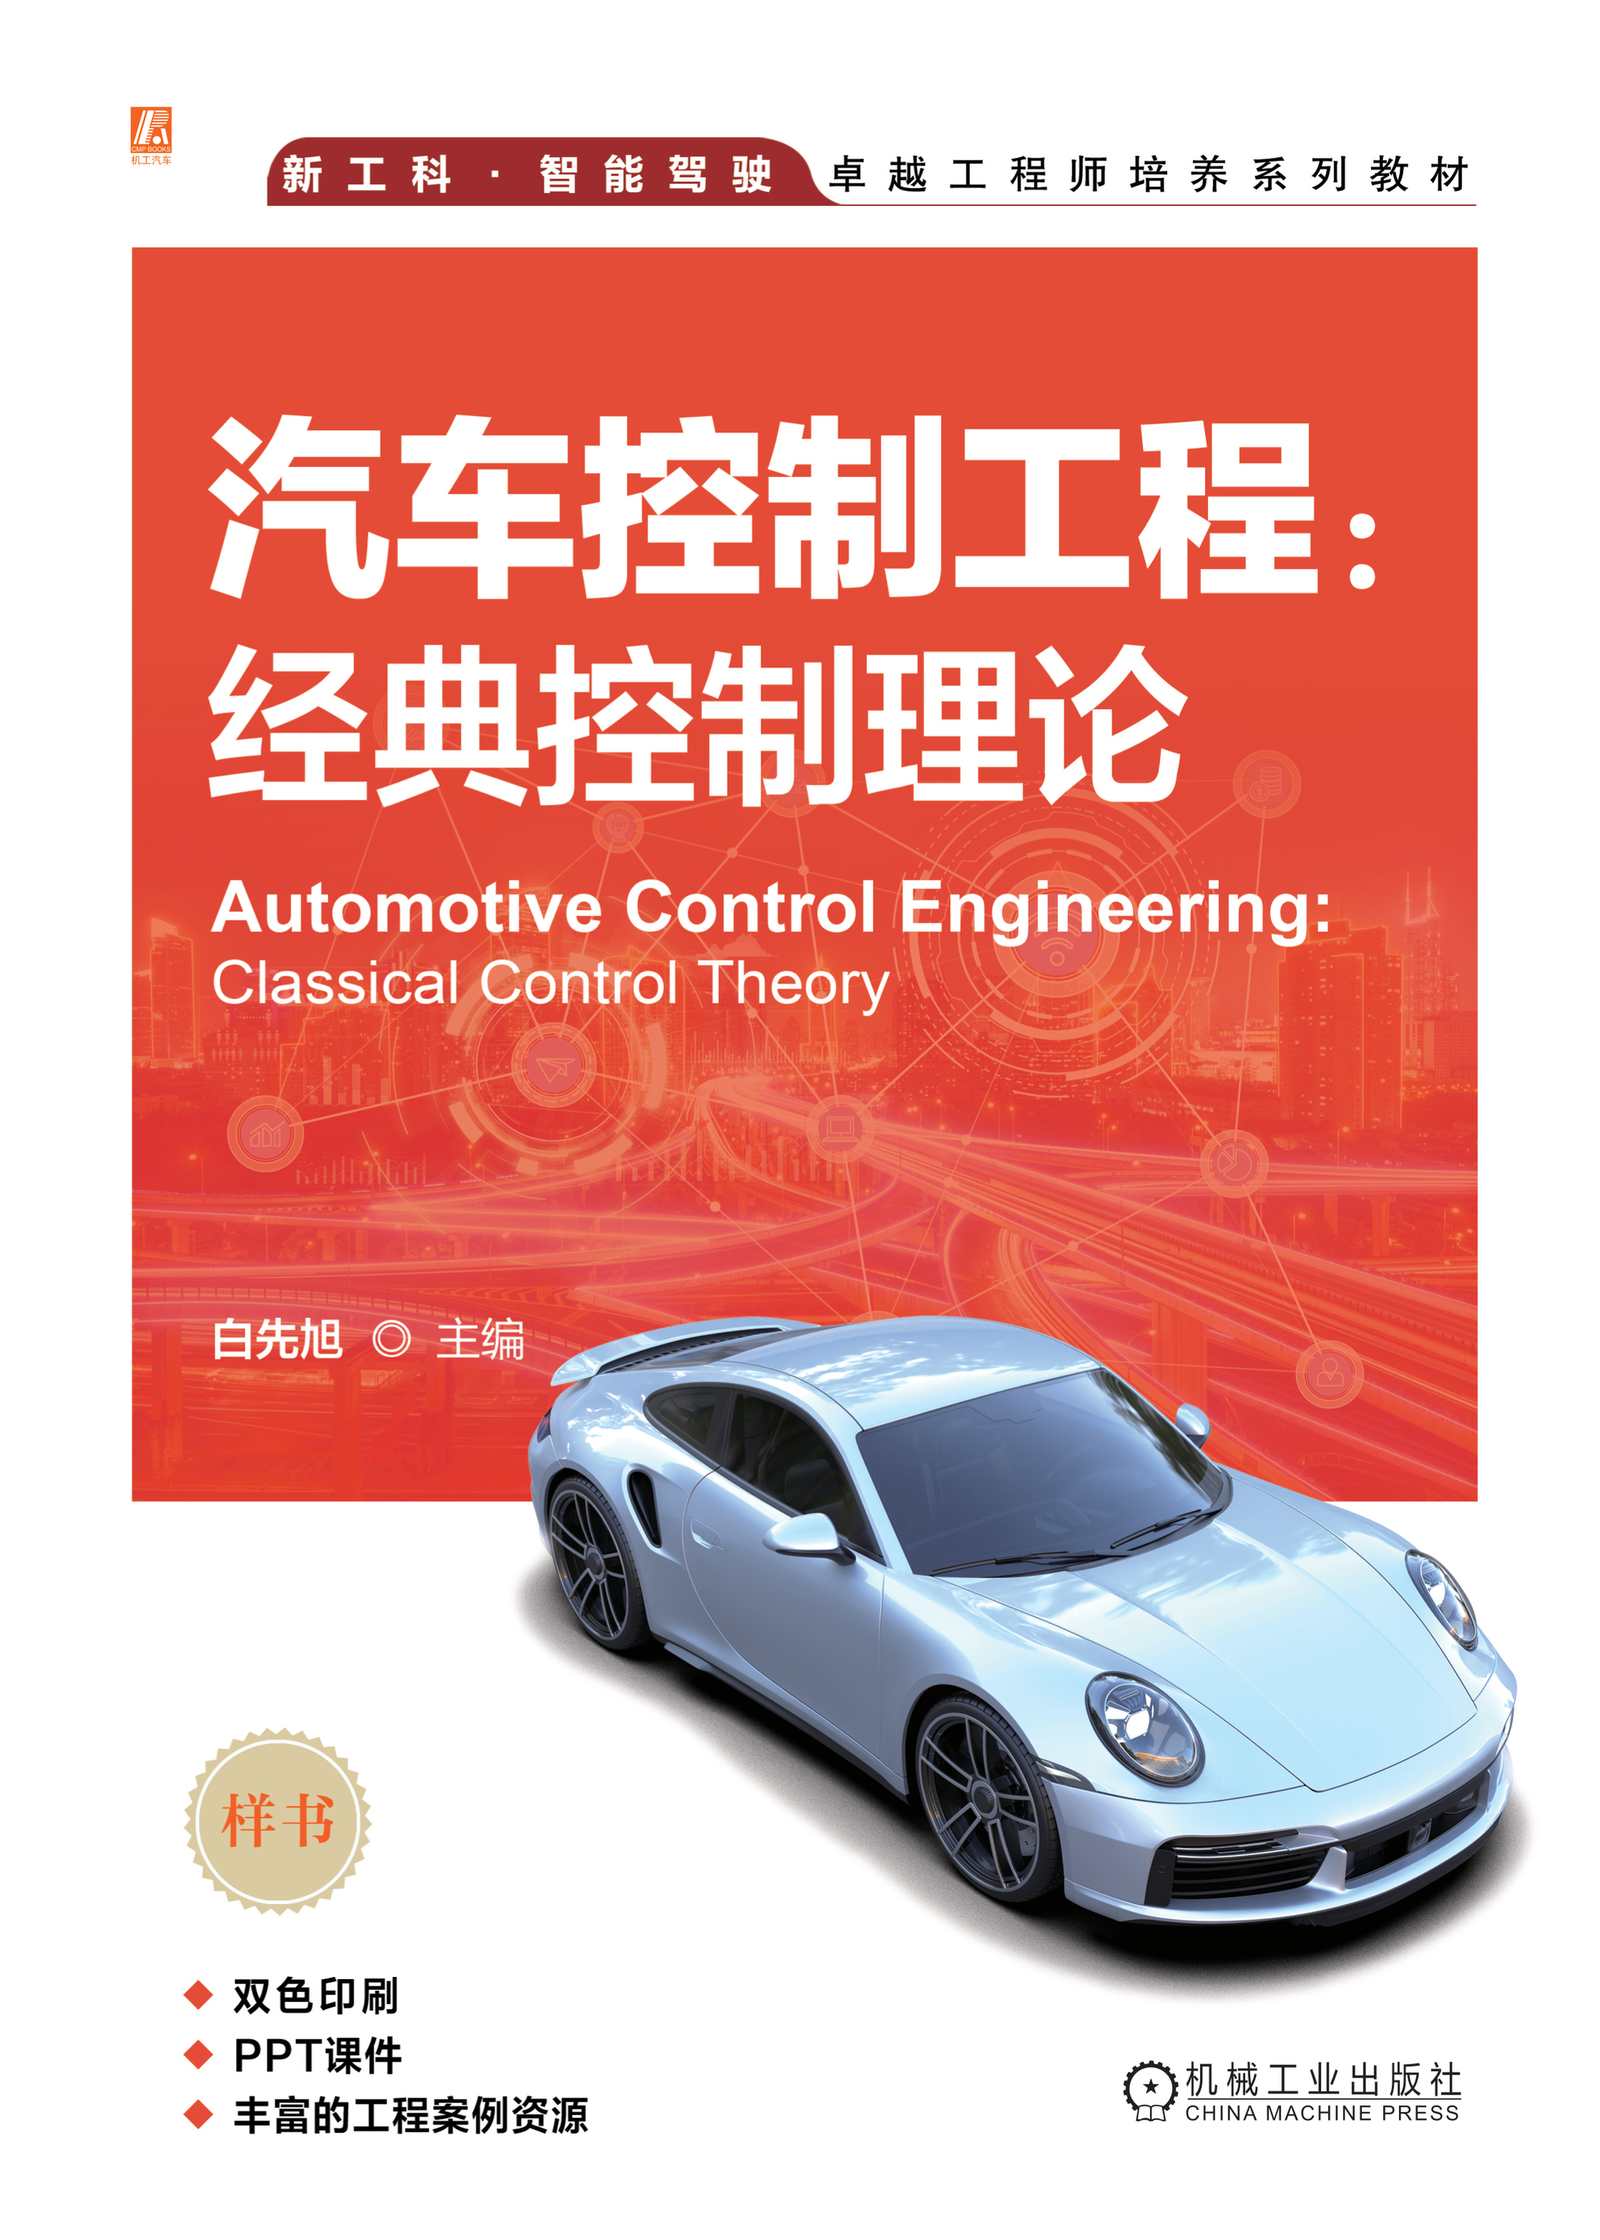
汽车控制工程:经典控制理论
白先旭(主编),祝安定、吴迪、陈进(副主编),李捷、陈刚群、陈朋、任恒、邵文彬(参编),汽车控制工程:经典控制理论,机械工业出版社出版,北京,2026年
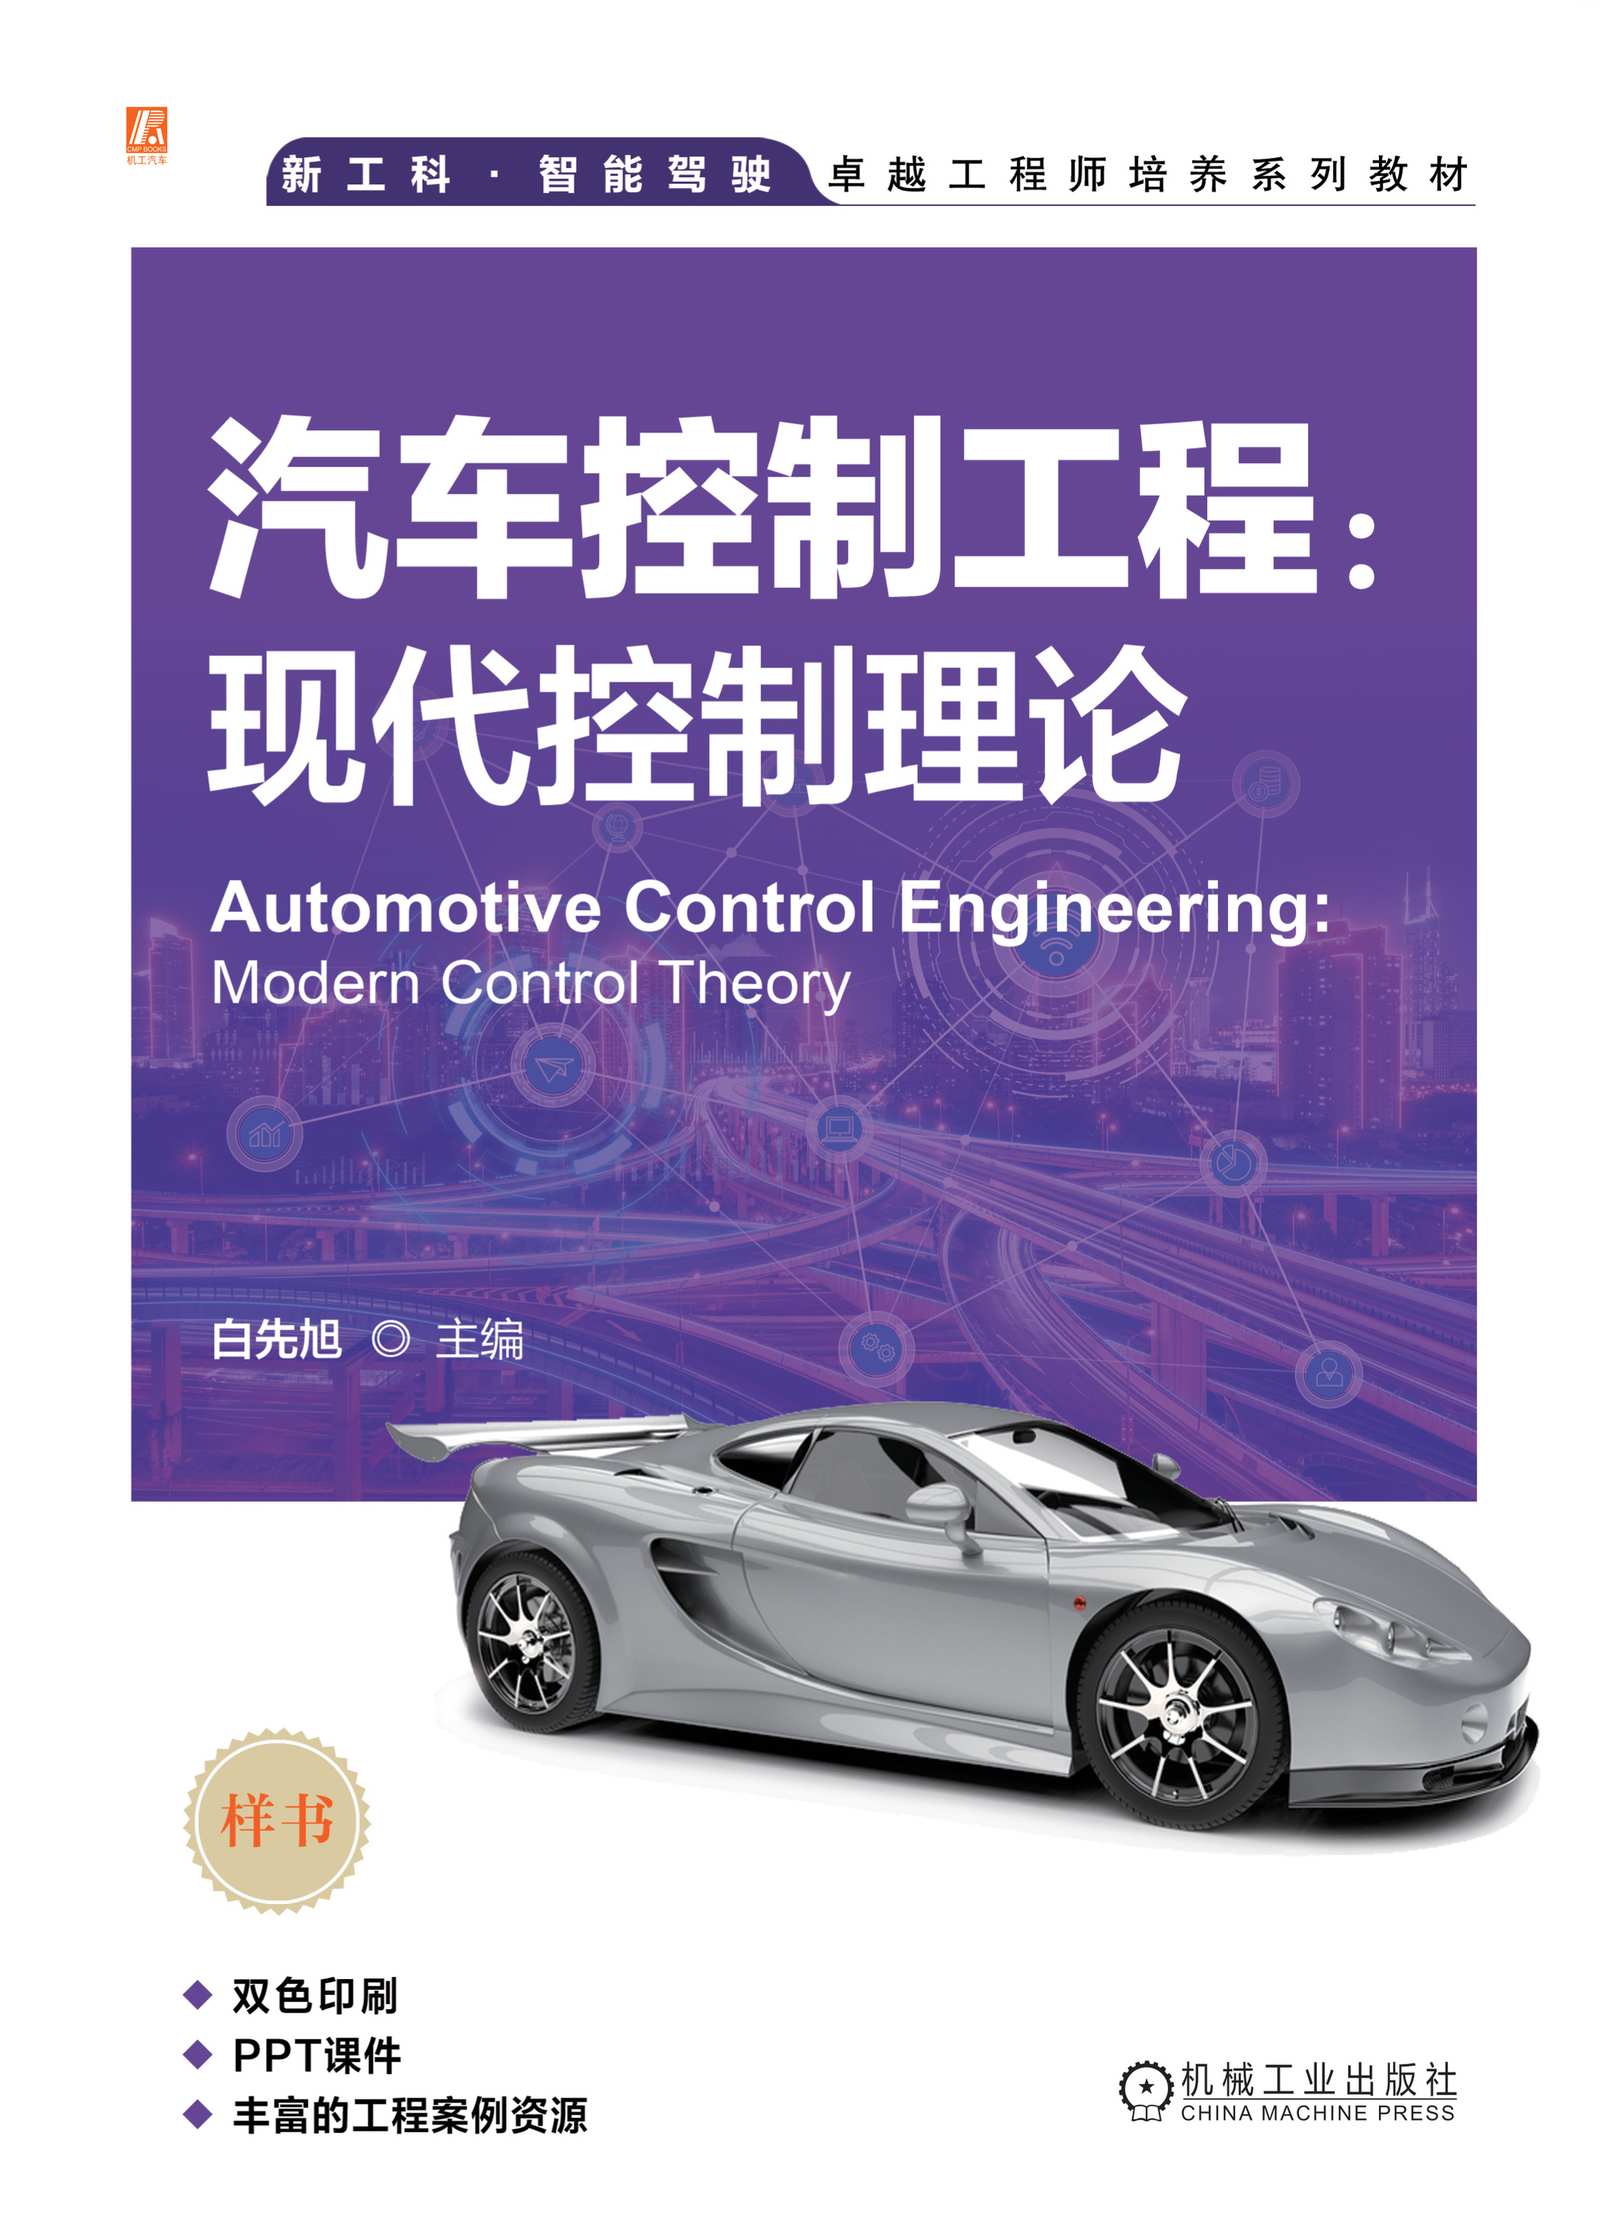
汽车控制工程:现代控制理论
白先旭(主编),祝安定、李道飞、李捷(副主编),陈进、陈刚群、陈朋、任恒、邵文彬(参编),汽车控制工程:现代控制理论,机械工业出版社出版,北京,2026年
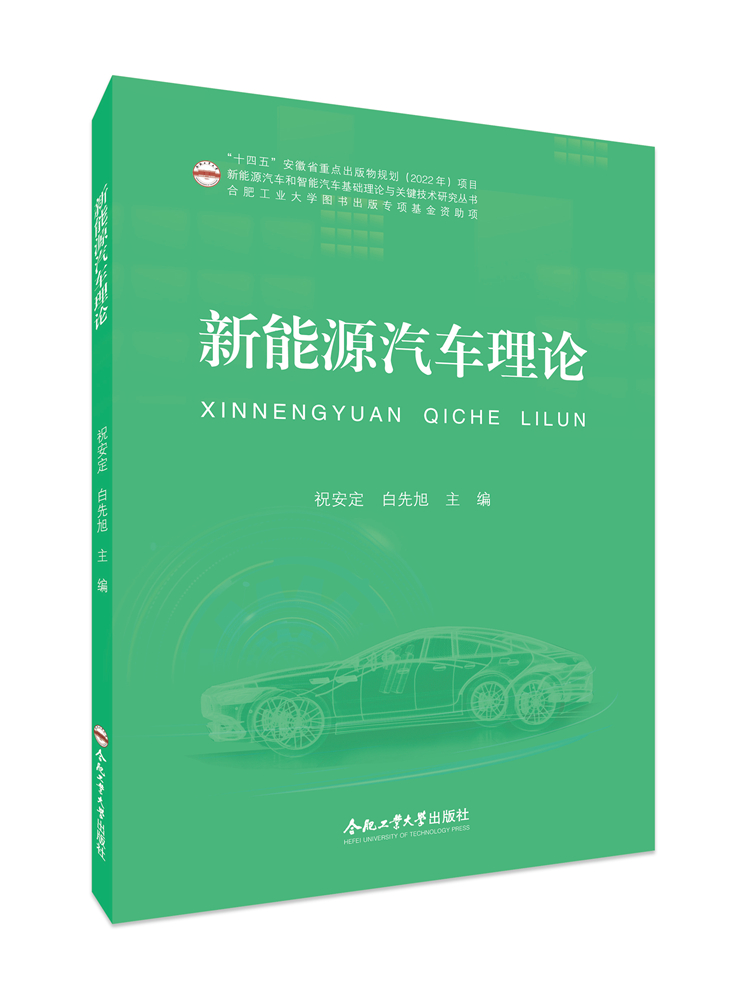
新能源汽车理论
祝安定 白先旭等,新能源汽车理论,合肥工业大学出版社,合肥,2025年
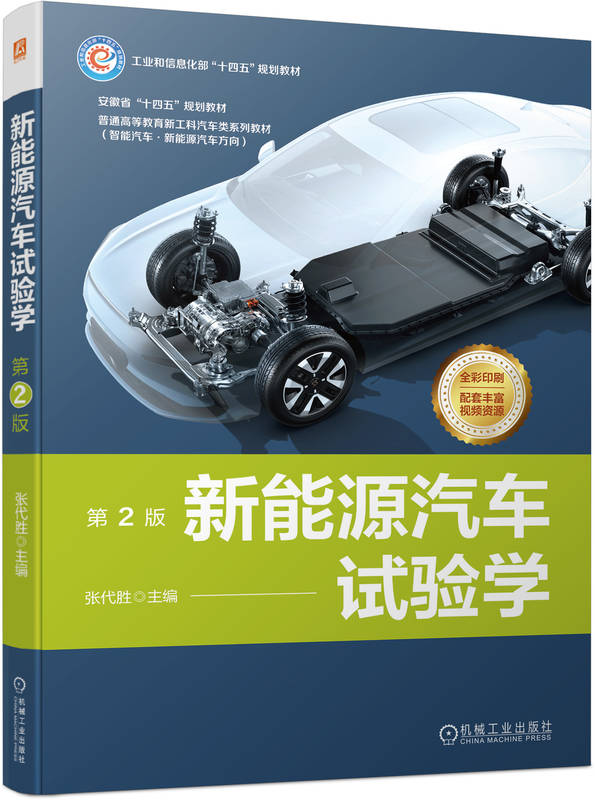
新能源汽车试验学(第2版)
白先旭等,新能源汽车试验学(第2版),机械工业出版社出版,北京,2025年(参编)
智能网联汽车预期功能安全测试评价关键技术
白先旭等,智能网联汽车预期功能安全测试评价关键技术,机械工业出版社,北京,2022年(参编)
教学配套 Teaching Support
总下载量:1,362
| 名称 Title | 简介 Description | 版本 Version | 更新时间 Last Updated | 下载次数 Downloads | 操作 Actions |
|---|---|---|---|---|---|
| 四分之一汽车主动悬架系统仿真模型 Quarter-Car Active Suspension System Simulation Model | 建立四分之一汽车悬架模型,分析路面激励下的车身与车轮垂向振动响应。 | V1.0 | 2026-10-21 | 85 | 下载 |
| 整车七自由度悬架系统仿真模型 Full-Vehicle Seven-Degree-of-Freedom Suspension System Simulation Model | 建立整车七自由度悬架模型,分析路面激励下的车身姿态与车轮振动响应。 | V1.0 | 2026-10-21 | 78 | 下载 |
| 电动助力转向系统仿真模型 Electric Power Steering System Simulation Model | 建立电动助力转向系统模型,分析转向输入作用下的系统动态响应。 | V1.0 | 2026-10-21 | 69 | 下载 |
| 汽车二自由度横向动力学仿真模型 Two-Degree-of-Freedom Vehicle Lateral Dynamics Simulation Model | 建立汽车二自由度横向动力学模型,分析转向输入下的车辆横向动态响应。 | V1.0 | 2026-10-21 | 86 | 下载 |
| 汽车导航定位系统能观性分析仿真模型 Vehicle Navigation and Localization System Observability Analysis Simulation Model | 建立汽车导航定位系统模型,分析系统状态与测量输出之间的关系。 | V1.0 | 2026-10-21 | 72 | 下载 |
| 磷酸铁锂电池SOC能观性分析仿真模型 Lithium Iron Phosphate Battery State-of-Charge Observability Analysis Simulation Model | 建立磷酸铁锂电池状态观测模型,分析SOC状态估计与能观性。 | V1.0 | 2026-10-21 | 70 | 下载 |
| 对开路面制动偏航控制与能控性分析仿真模型 Split-Friction Road Braking Yaw Control and Controllability Analysis Simulation Model | 建立对开路面车辆制动模型,分析制动过程中的偏航响应与控制效果。 | V1.0 | 2026-10-21 | 63 | 下载 |
| 汽车ESP横摆稳定性分析仿真模型 Vehicle Electronic Stability Program Yaw Stability Analysis Simulation Model | 建立汽车ESP控制模型,分析控制作用下的车辆横摆响应与稳定性。 | V1.0 | 2026-10-21 | 63 | 下载 |
| 二自由度四轮转向汽车解耦控制与状态观测仿真模型 Two-Degree-of-Freedom Four-Wheel-Steering Vehicle Decoupling Control and State Estimation Simulation Model | 建立四轮转向汽车控制模型,分析解耦控制与车辆状态观测效果。 | V1.0 | 2026-10-21 | 72 | 下载 |
| 汽车横摆角速度跟踪与抗侧风扰动控制仿真模型 Vehicle Yaw Rate Tracking and Crosswind Disturbance Rejection Control Simulation Model | 建立汽车横摆控制模型,分析横摆角速度跟踪与侧风扰动抑制效果。 | V1.0 | 2026-10-21 | 56 | 下载 |
| 基于KF的汽车横向状态估计仿真模型 Kalman Filter-Based Vehicle Lateral State Estimation Simulation Model | 建立汽车横向状态估计模型,分析卡尔曼滤波方法的状态估计效果。 | V1.0 | 2026-10-21 | 58 | 下载 |
| 基于动态规划的并联式混合动力汽车能量管理策略 Dynamic Programming-Based Parallel Hybrid Electric Vehicle Energy Management Simulation Model | 建立并联式混合动力汽车能量管理模型,基于动态规划优化发动机与电机的转矩分配,分析燃油消耗及动力电池荷电状态变化。 | V1.0 | 2026-10-26 | 66 | 下载 |
| 基于LQR的汽车主动后轮转向控制仿真模型 LQR-Based Vehicle Active Rear-Wheel Steering Control Simulation Model | 基于LQR方法建立主动后轮转向控制模型,分析车辆横向动态响应。 | V1.0 | 2026-10-21 | 64 | 下载 |
| 基于LQR的汽车纵向速度跟踪控制仿真模型 LQR-Based Vehicle Longitudinal Speed Tracking Control Simulation Model | 基于LQR方法建立纵向速度控制模型,分析车辆速度跟踪性能。 | V1.0 | 2026-10-21 | 73 | 下载 |
| 基于MPC的汽车纵向速度跟踪仿真模型 MPC-Based Vehicle Longitudinal Speed Tracking Simulation Model | 基于MPC方法建立纵向速度控制模型,分析车辆速度跟踪性能。 | V1.0 | 2026-10-21 | 77 | 下载 |
| 基于MPC的汽车轨迹跟踪仿真模型 MPC-Based Vehicle Trajectory Tracking Simulation Model | 基于MPC方法建立车辆轨迹跟踪模型,分析横向位置与航向跟踪误差。 | V1.0 | 2026-10-21 | 52 | 下载 |
| 基于MPC的汽车侧倾稳定性控制仿真模型 MPC-Based Vehicle Roll Stability Control Simulation Model | 基于MPC方法建立车身侧倾控制模型,分析车辆侧倾响应与控制性能。 | V1.0 | 2026-10-21 | 66 | 下载 |
| 基于MPC的汽车横垂向交互控制仿真模型 MPC-Based Vehicle Lateral–Vertical Coupled Control Simulation Model | 基于MPC方法建立车辆横垂向控制模型,分析横向与垂向运动响应。 | V1.0 | 2026-10-21 | 66 | 下载 |
| 定速巡航系统传递函数分析 Cruise Control System Transfer Function Analysis | 建立定速巡航系统数学模型,分析系统传递函数及零极点特性。 | V1.0 | 2026-10-25 | 64 | 下载 |
| 线控转向系统传递函数分析 Steer-by-Wire System Transfer Function Analysis | 建立线控转向系统数学模型,分析系统传递函数及零极点特性。 | V1.0 | 2026-10-25 | 56 | 下载 |
第 1 页 / 共 2 页
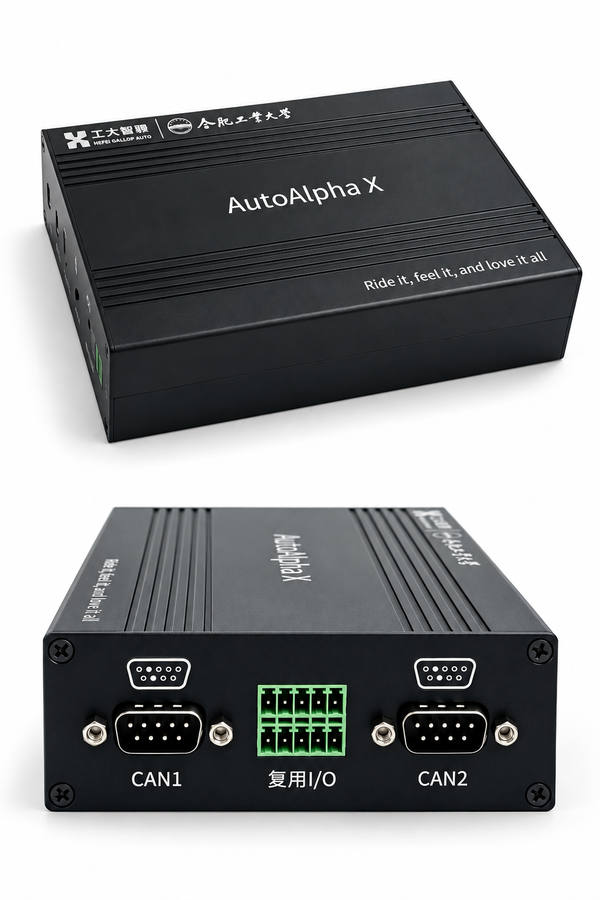
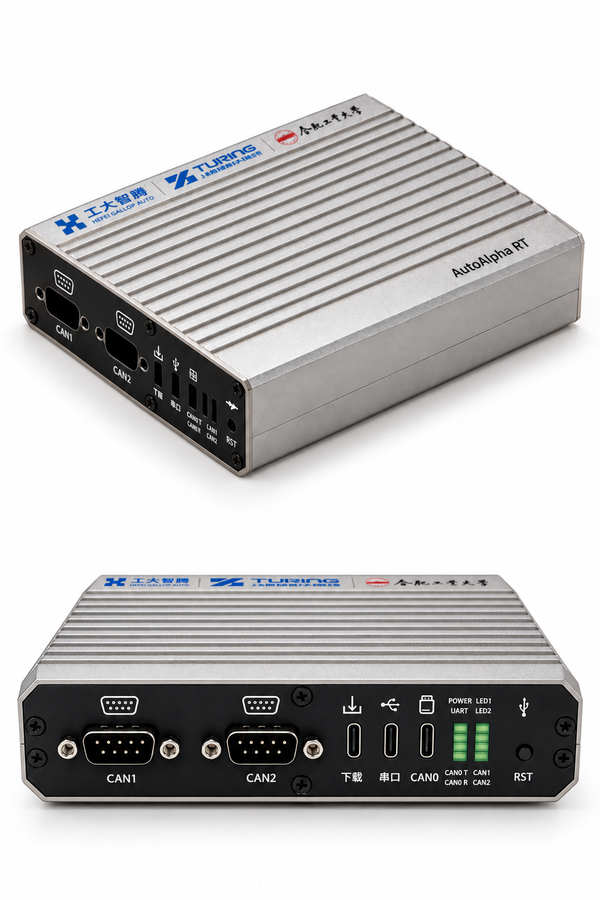
| 名称 Title | 简介 Description | 版本 Version | 更新时间 Last Updated | 下载次数 Downloads | 操作 Actions |
|---|---|---|---|---|---|
| 暂无已发布资源,敬请期待。 | |||||
问题与建议 Questions & Suggestions
如您在使用教学资源或本网站时遇到问题,或有改进建议,欢迎通过下方方式向我们反馈。您的反馈将帮助我们持续提升教学资源质量,改善网站使用体验。If you encounter any questions with the teaching resources or this website, or have suggestions for improvement, please submit your feedback using the options below. Your feedback will help us improve the quality of the teaching resources and the experience of using this website.
提交反馈 Submit Feedback